Publications
2026
Christoffel-Consistent Coriolis Factorization and Its Effect on the Control of a Robot
Jonghyeok Kim and Wan Kyun Chung
IEEE Robotics and Automation Letters (RA-L)
[IEEE] 2025
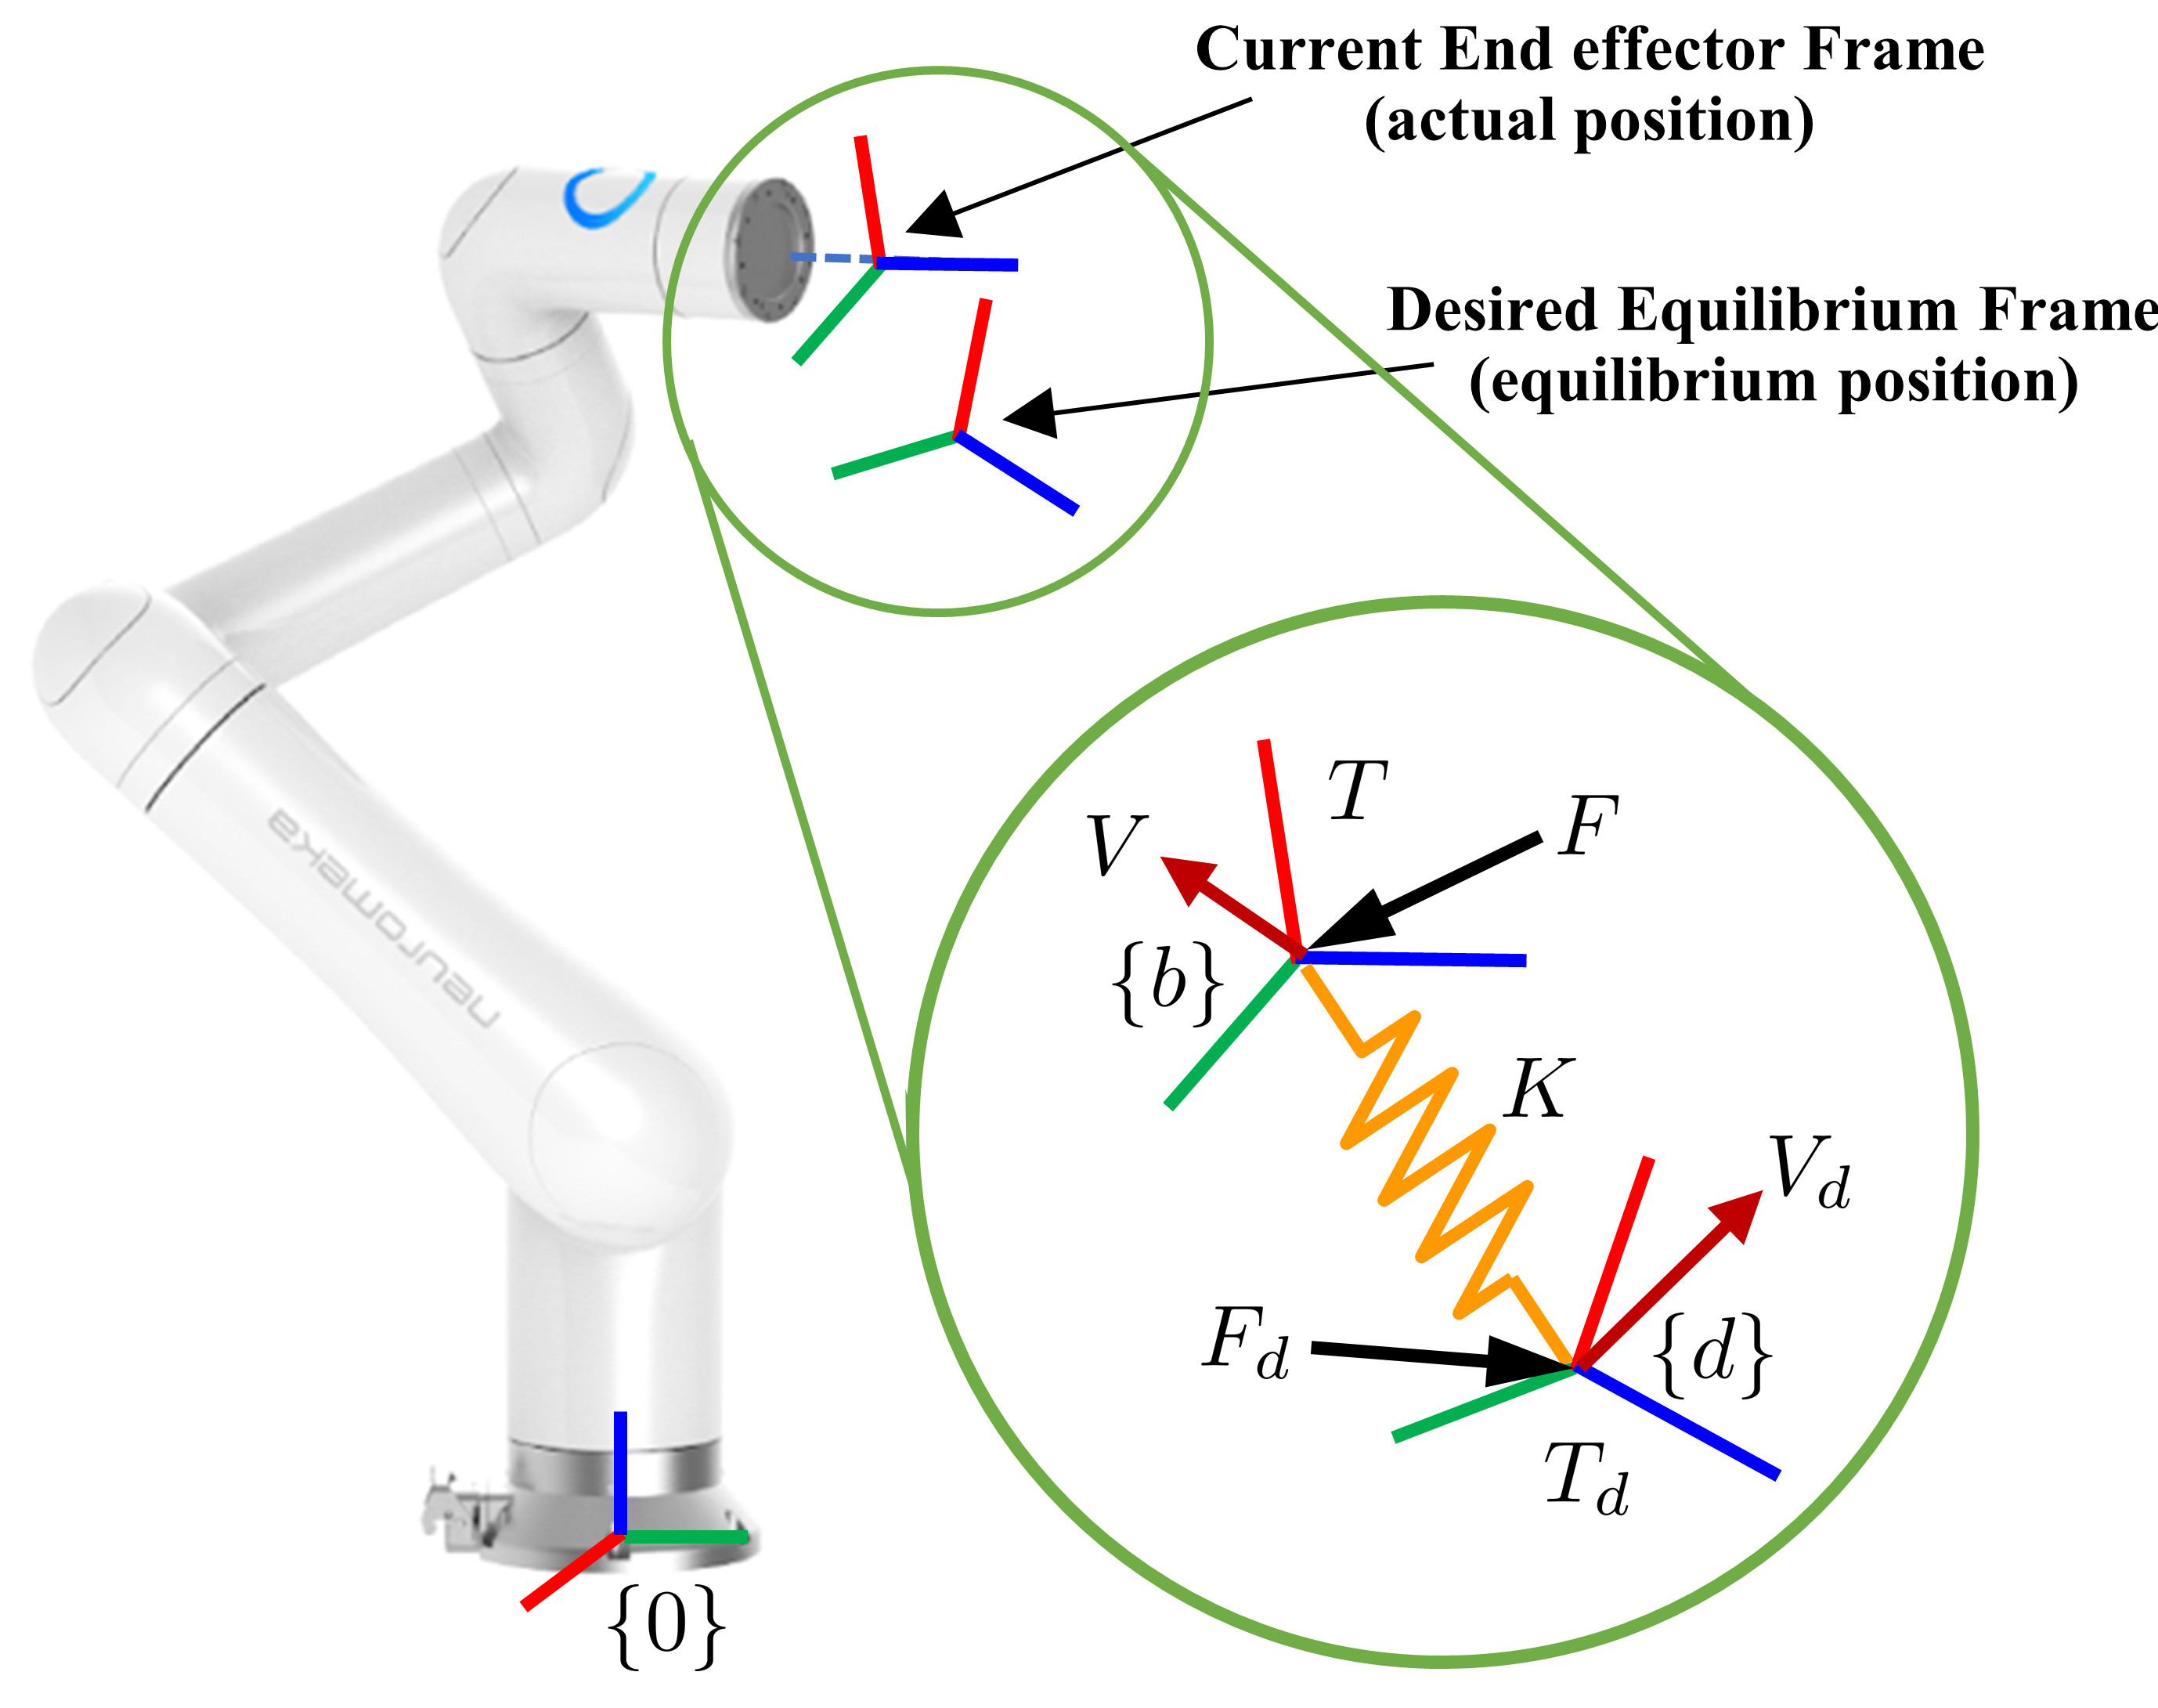
Impedance Control Design Framework Using Commutative Map Between SE(3) and se(3)
Jonghyeok Kim, Minchang Sung, Youngjin Choi, Jonghoon Park, and Wan Kyun Chung
IEEE Transactions on Robotics (T-RO)
[IEEE] 2024
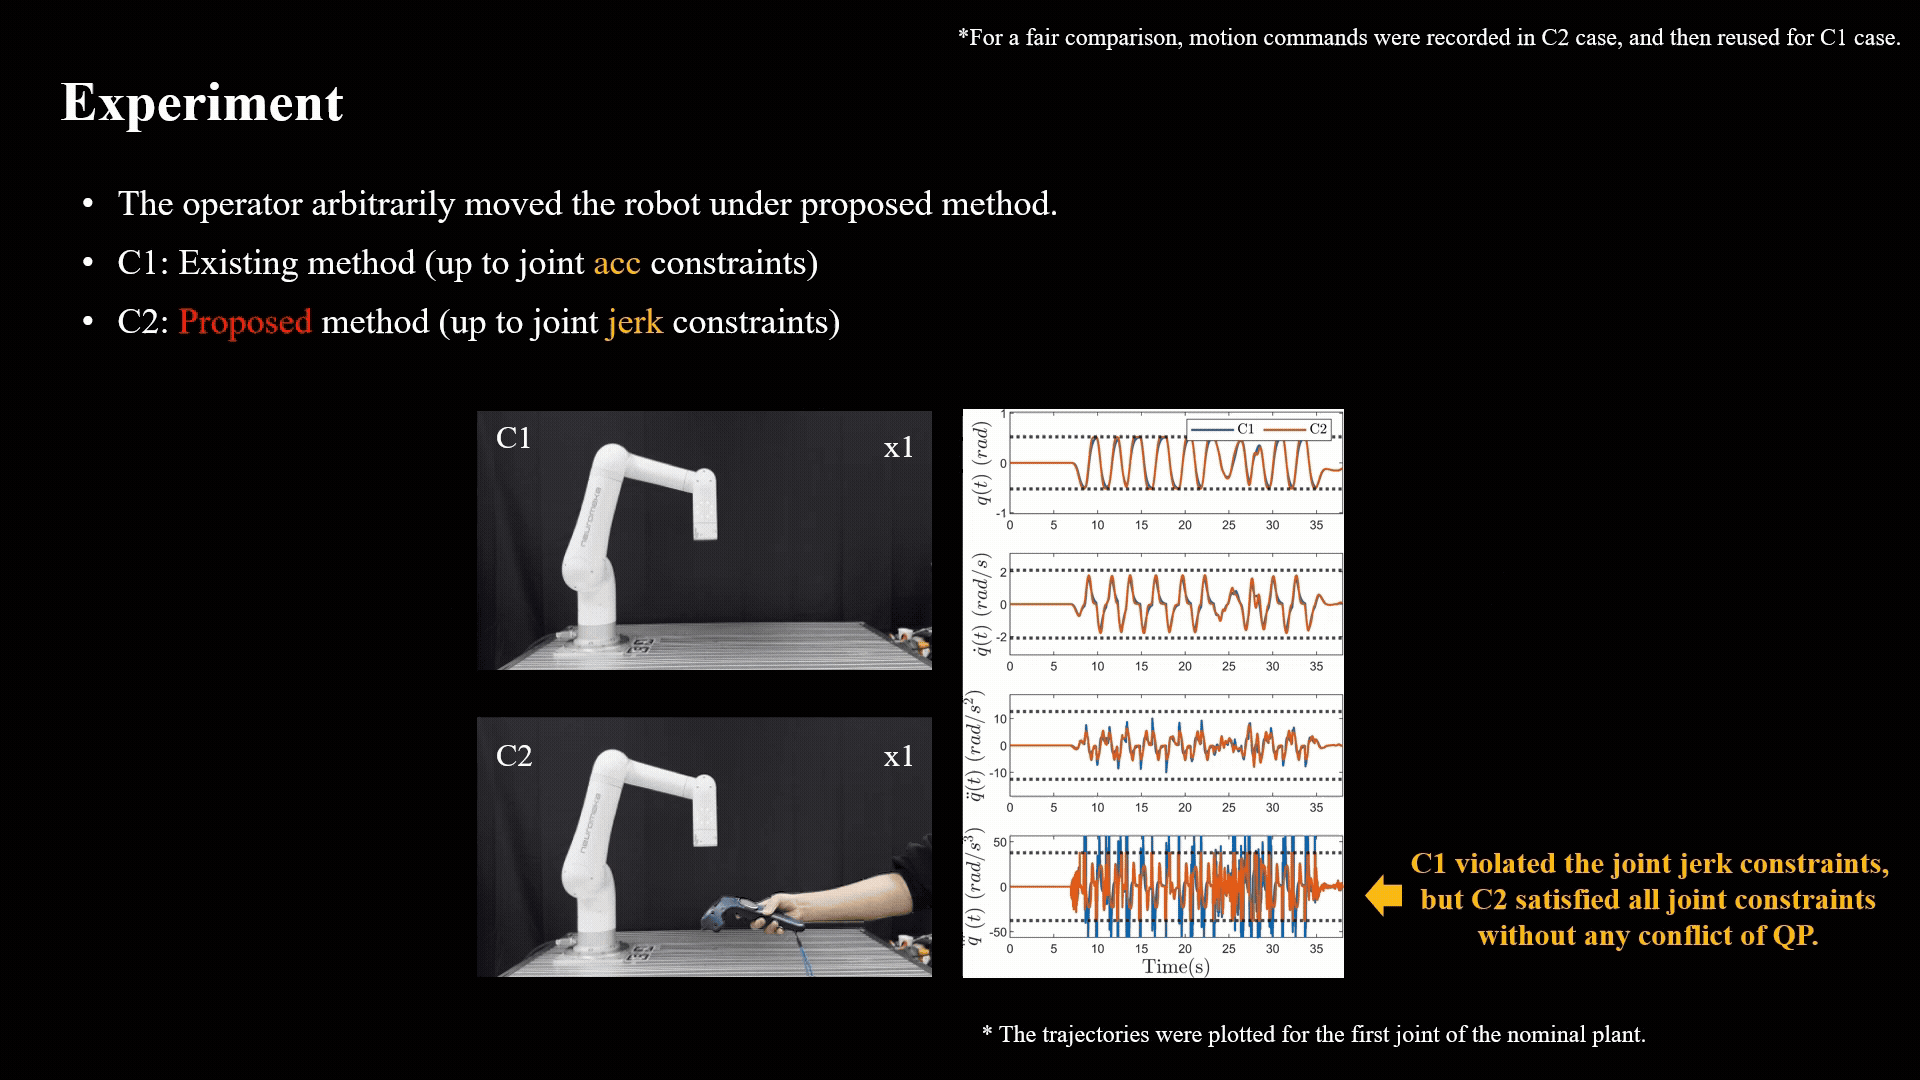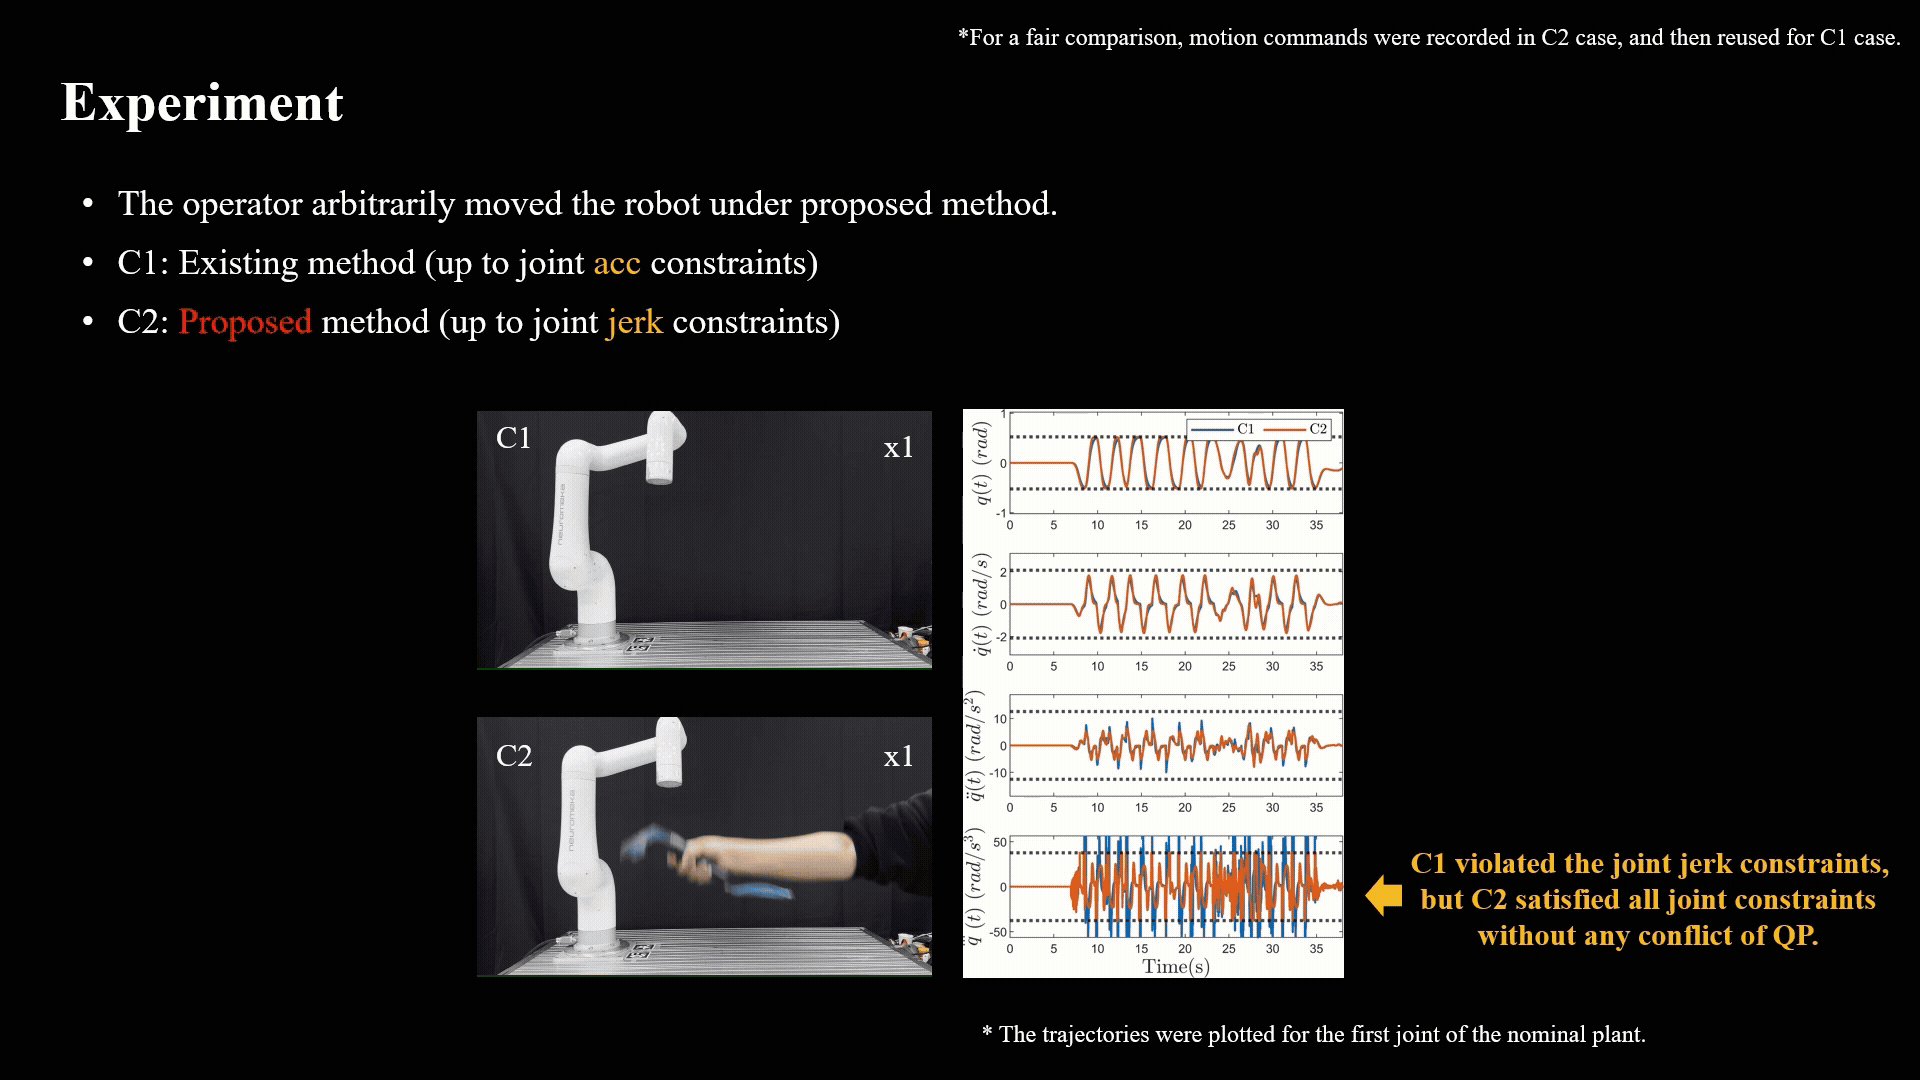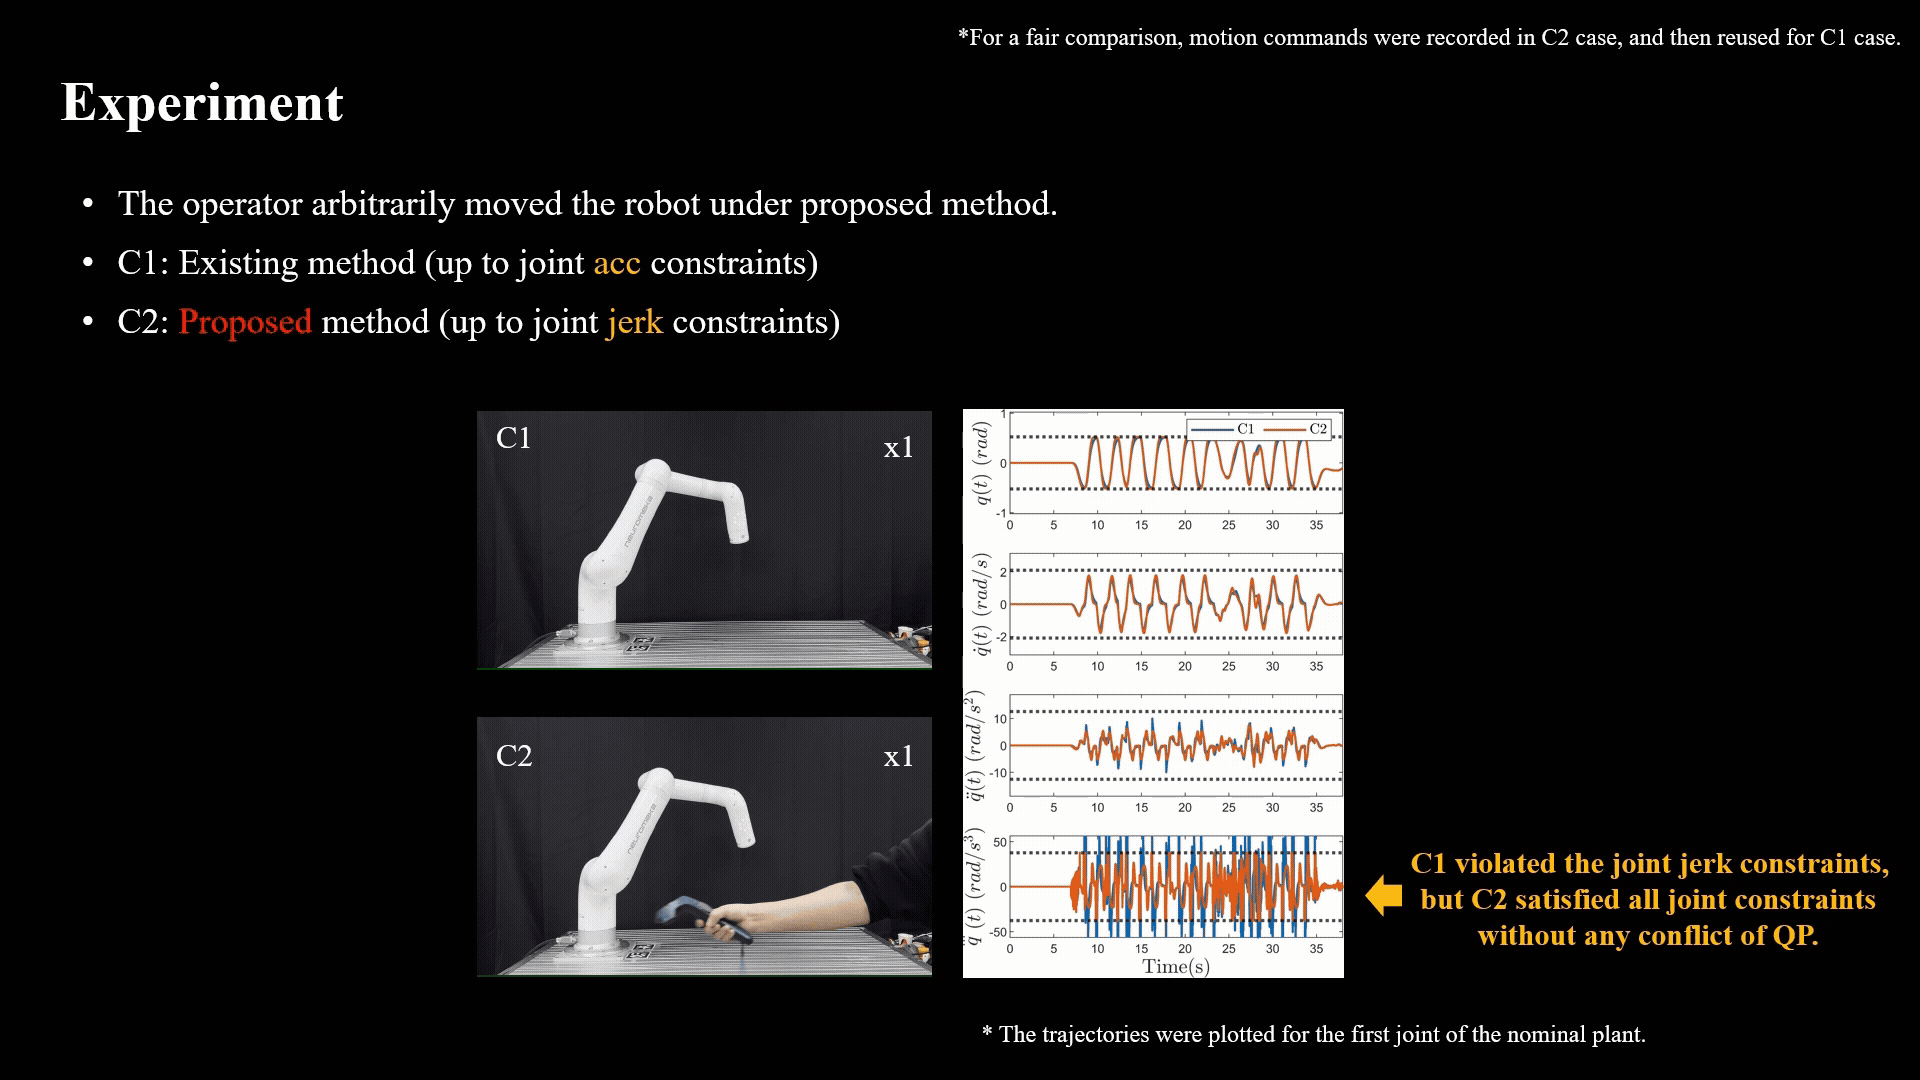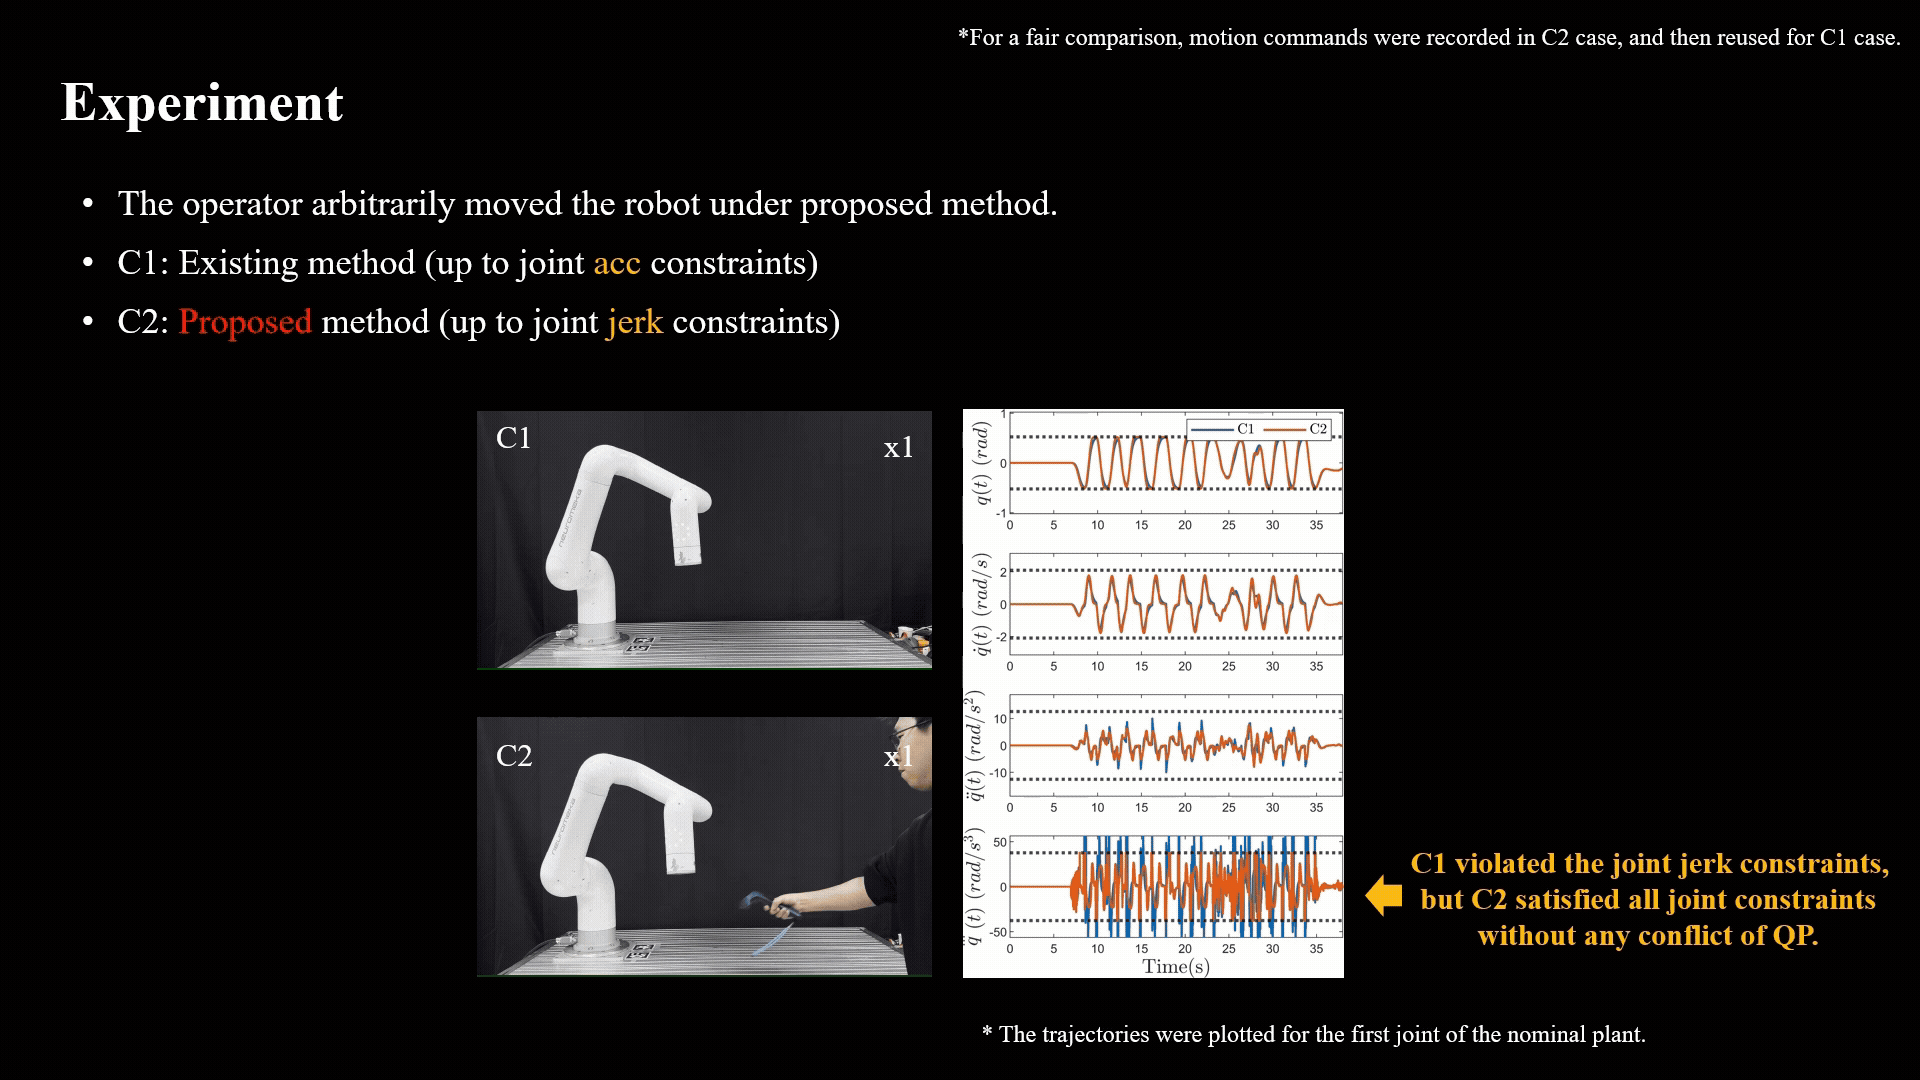
Ensuring Joint Constraints of Torque-Controlled Robot Manipulators under Bounded Jerk
Dongwoo Ko, Jonghyeok Kim, and Wan Kyun Chung
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
[IEEE] 
Lie Group-Based User Motion Refinement Control for Teleoperation of a Constrained Robot Arm
Jonghyeok Kim, Donghyeon Lee, Youngjin Choi, and Wan Kyun Chung
IEEE Robotics and Automation Letters (RA-L)
[IEEE] 2026
- H. Jung, J. Kim and K. Kim, “Learning Spatially Ambiguous Trajectories from Demonstrations via Phase-Modulated Dynamical Systems,” IEEE Robotics and Automation Letters (RA-L) , (Accepted)
- J. Kim and W. K. Chung, “Christoffel-Consistent Coriolis Factorization and Its Effect on the Control of a Robot,” IEEE Robotics and Automation Letters (RA-L) , (This work will be presented at IROS 2026, Pittsburgh, USA)
2025
- J. Kim, M. Sung, Y. Choi, J. Park, and W. K. Chung, “Impedance Control Design Framework Using Commutative Map Between SE(3) and se(3),” IEEE Transactions on Robotics (T-RO) , (This work will be presented at ICRA 2026, Vienna, Austria)
- S. Choi, J. Kim, and W. K. Chung, “Deep Learning-Based Friction Compensation in Low Velocity for Enhanced Direct Teaching in Collaborative Manipulators,” IEEE International Conference on Robotics and Automation (ICRA) 2025 , Atlanta, USA
- J. Kim, Y. Choi, J. Park, and W. K. Chung, “A Passive Recursive Newton Euler Algorithm and Its Application to Inverse Dynamics under Passivity-based Controller,” IEEE International Conference on Simulation, Modeling, and Programming for Autonomous Robots (SIMPAR) 2025 , Palermo, Italy
2024
- D. Ko, J. Kim, and W. K. Chung, “Ensuring Joint Constraints of Torque-Controlled Robot Manipulators under Bounded Jerk,” IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2024 , Abu-Dhabi, UAE
- J. Kim, D. Lee, Y. Choi, and W. K. Chung, “Lie Group-Based User Motion Refinement Control for Teleoperation of a Constrained Robot Arm,” IEEE Robotics and Automation Letters (RA-L) , (This work was presented at IROS 2024, Abu-Dhabi, UAE)